|
Wenkai Guo (郭文锴) Hi! I'm currently a PhD student in PINE Lab at Nanyang Technological University (NTU) supervised by Professor Wang Ziwei. Previously, I graduated as a MSc from NTU. I received my BEng in School of Automation at Southeast University, supervised by Professor Li Shihua, Professor Du Songlin, and Professor Wang Yangang. My research interests lie in robotic foundation models and reinforcement learning. My research goal is to build trustworthy robot intelligence. Specifically, my attention is caught by: 1. Simple solution for complex problems; 2. Scalability in depth and width. Email / Google Scholar / LinkedIn / GitHub |
Taken in Wien, 2026 |
BlogsI write here to focus when it matters, and to wander when it helps. |
News
|
Recent Works |
|
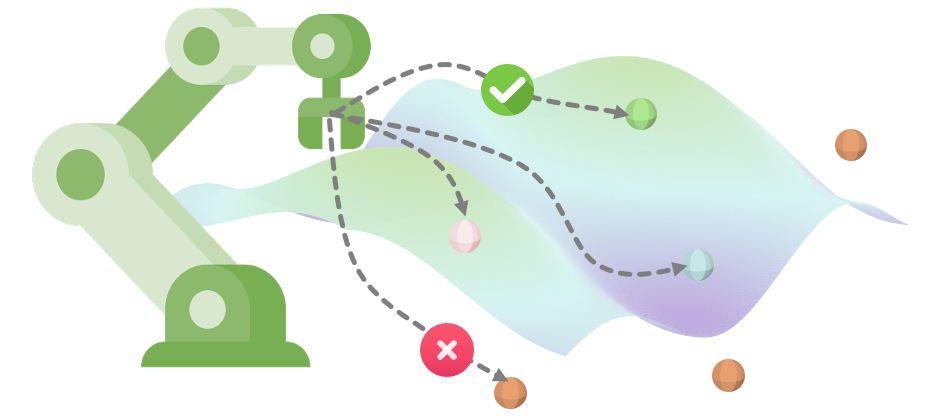
REMA: Efficient Online Robotic Reinforcement Learning with Explicit Manifold Alignment
Wenkai Guo, Peizhi Tang, Yukun Bai, Ziming Yan, Haoyuan Deng, Guanxing Lu, Shijie Li, Ziwei Wang IEEE Robotics and Automation Letters (RA-L), 2026 project page / IEEE Xplore / arXiv (coming soon) / code (coming soon) |
|
VLA-RL: Towards Masterful and General Robotic Manipulation with Scalable Reinforcement Learning
Guanxing Lu, Wenkai Guo, Chubin Zhang, Yuheng Zhou, Haonan Jiang, Zifeng Gao, Yansong Tang, Ziwei Wang IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026 project page / arXiv / code |
|
|
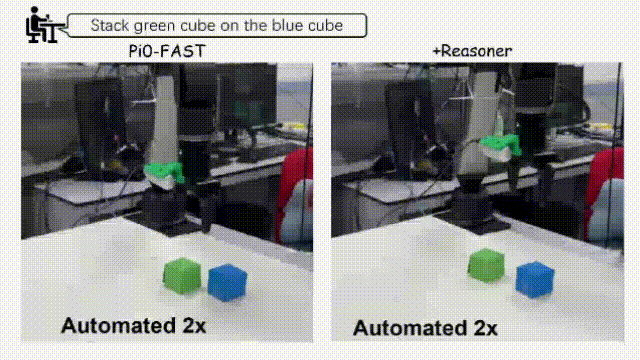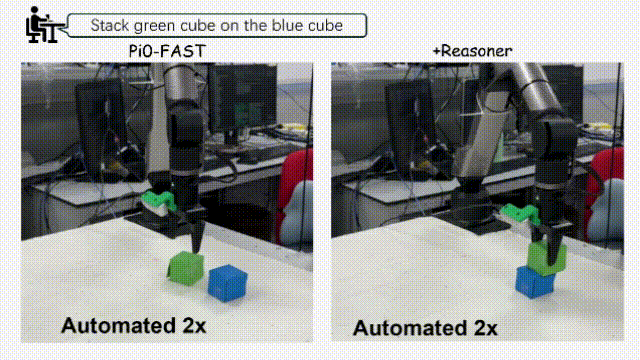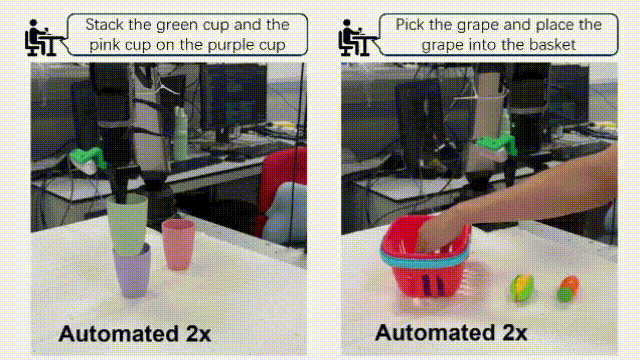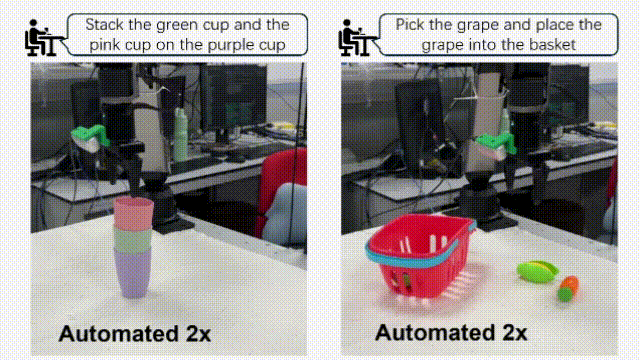
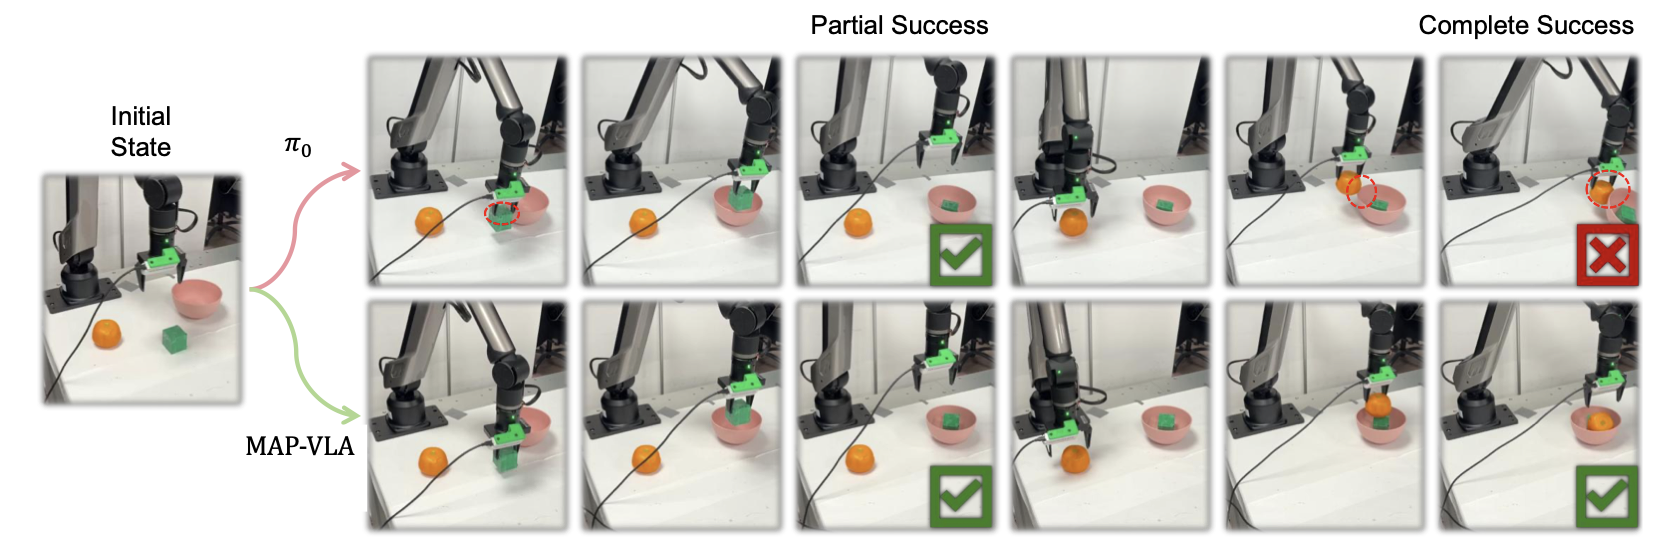
VLA-Reasoner: Empowering Vision-Language-Action Models with Reasoning via Online Monte Carlo Tree Search
Wenkai Guo*, Guanxing Lu*, Haoyuan Deng, Zhenyu Wu, Yansong Tang, Ziwei Wang IEEE International Conference on Robotics and Automation (ICRA), 2026 project page / arXiv / code |
|
Map-VLA: Memory-Augmented Prompting for Vision-Language-Action Model in Robotic Manipulation
Runhao Li, Wenkai Guo, Zhenyu Wu, Changyuan Wang, Haoyuan Deng, Zhenyu Weng, Yap-Peng Tan, Ziwei Wang IEEE International Conference on Robotics and Automation (ICRA), 2026 project page / arXiv |
|
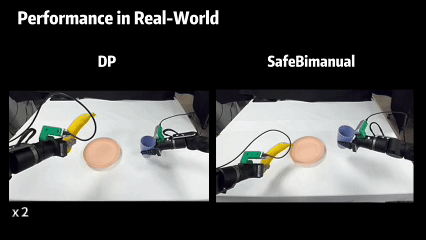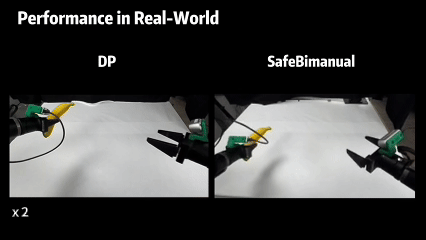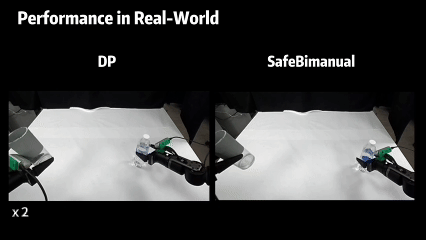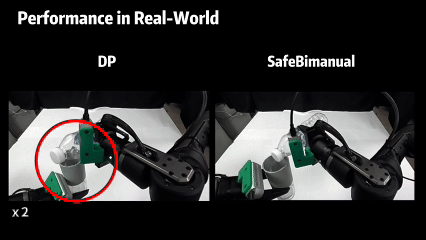
SafeBimanual: Diffusion-based Trajectory Optimization for Safe Bimanual Manipulation
Haoyuan Deng, Wenkai Guo, Qianzhun Wang, Zhenyu Wu, Ziwei Wang 9th Conference on Robot Learning (CoRL), 2025 project page / arXiv |
Academic ServicesJournal Reviewer: RA-L Conference Reviewer: ICLR, ICRA, IROS, CoRL, ICCV, AAAI |
|
Total views: | Visitors: Map: visits since September 2026 |
|
|